01
WORK PROJECT
Built as MajorProject while doing my Bachelors
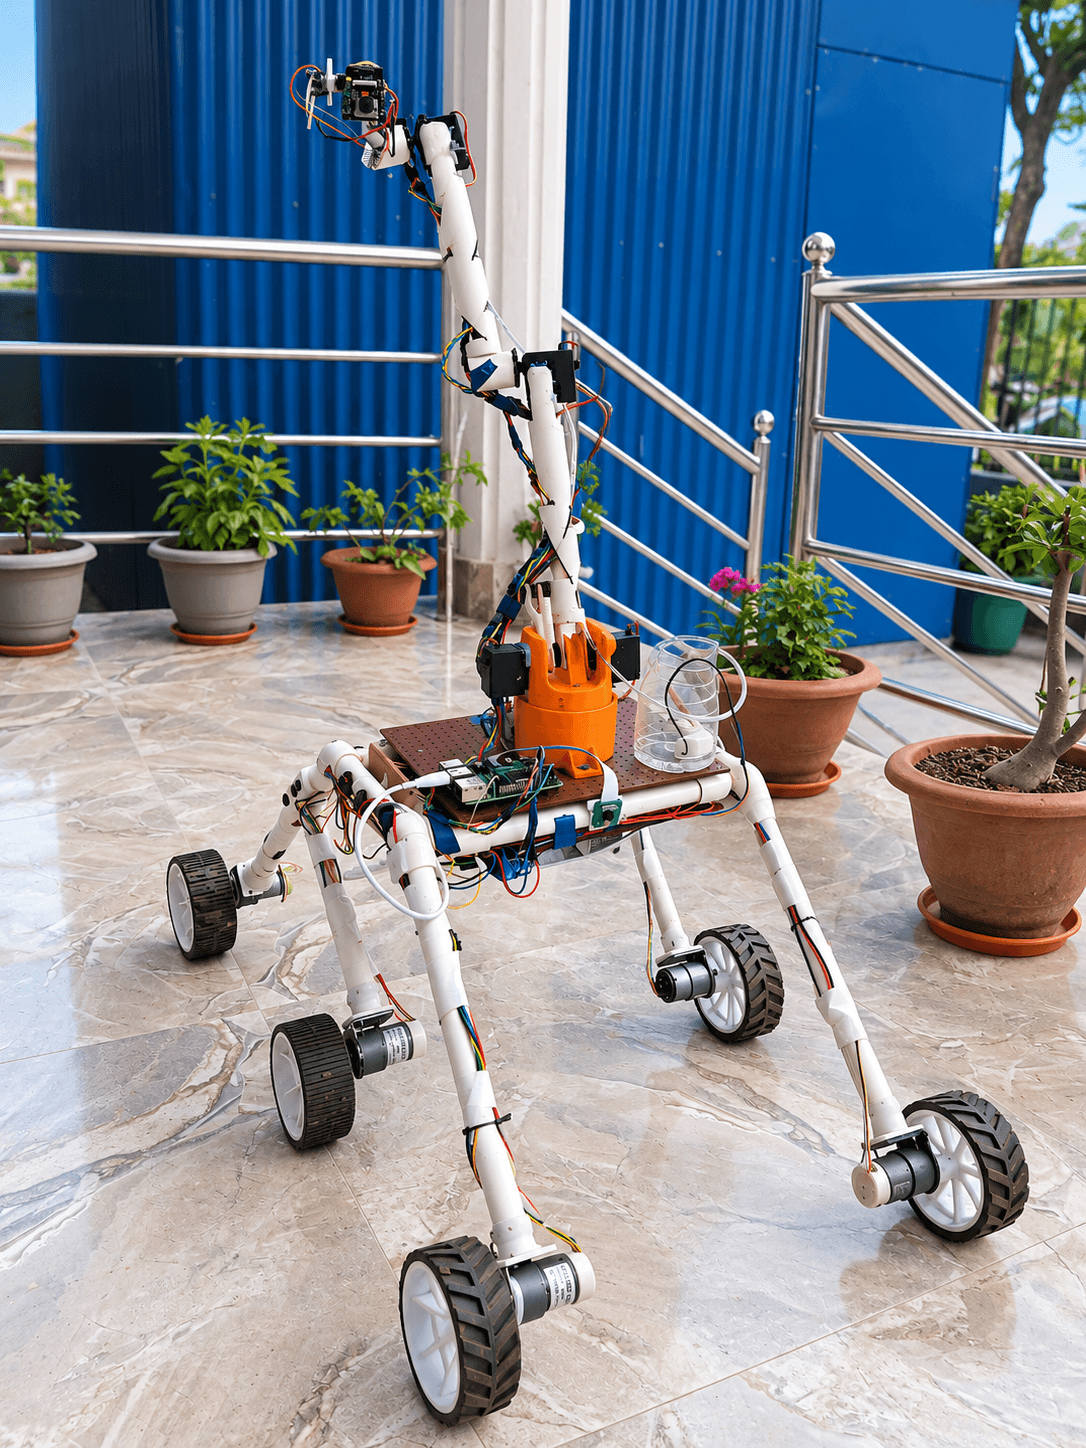
Agribot
A multidisciplinary mobile robot project spanning mechanical design, embedded control, computer vision, and ROS 2 integration.
Based in Lalitpur, Nepal
Electronics and communication engineering student working across autonomous robots, embedded systems, and computer vision.
ROS 2 · Computer vision · Embedded control
Selected work
Built as MajorProject while doing my Bachelors
A multidisciplinary mobile robot project spanning mechanical design, embedded control, computer vision, and ROS 2 integration.
Built at GarudX · Delivered to Nepal Police
An AI-enabled UAV ecosystem for surveillance, tracking, traffic intelligence, search and rescue, and mission-specific payload operations.
Explore the project story ↗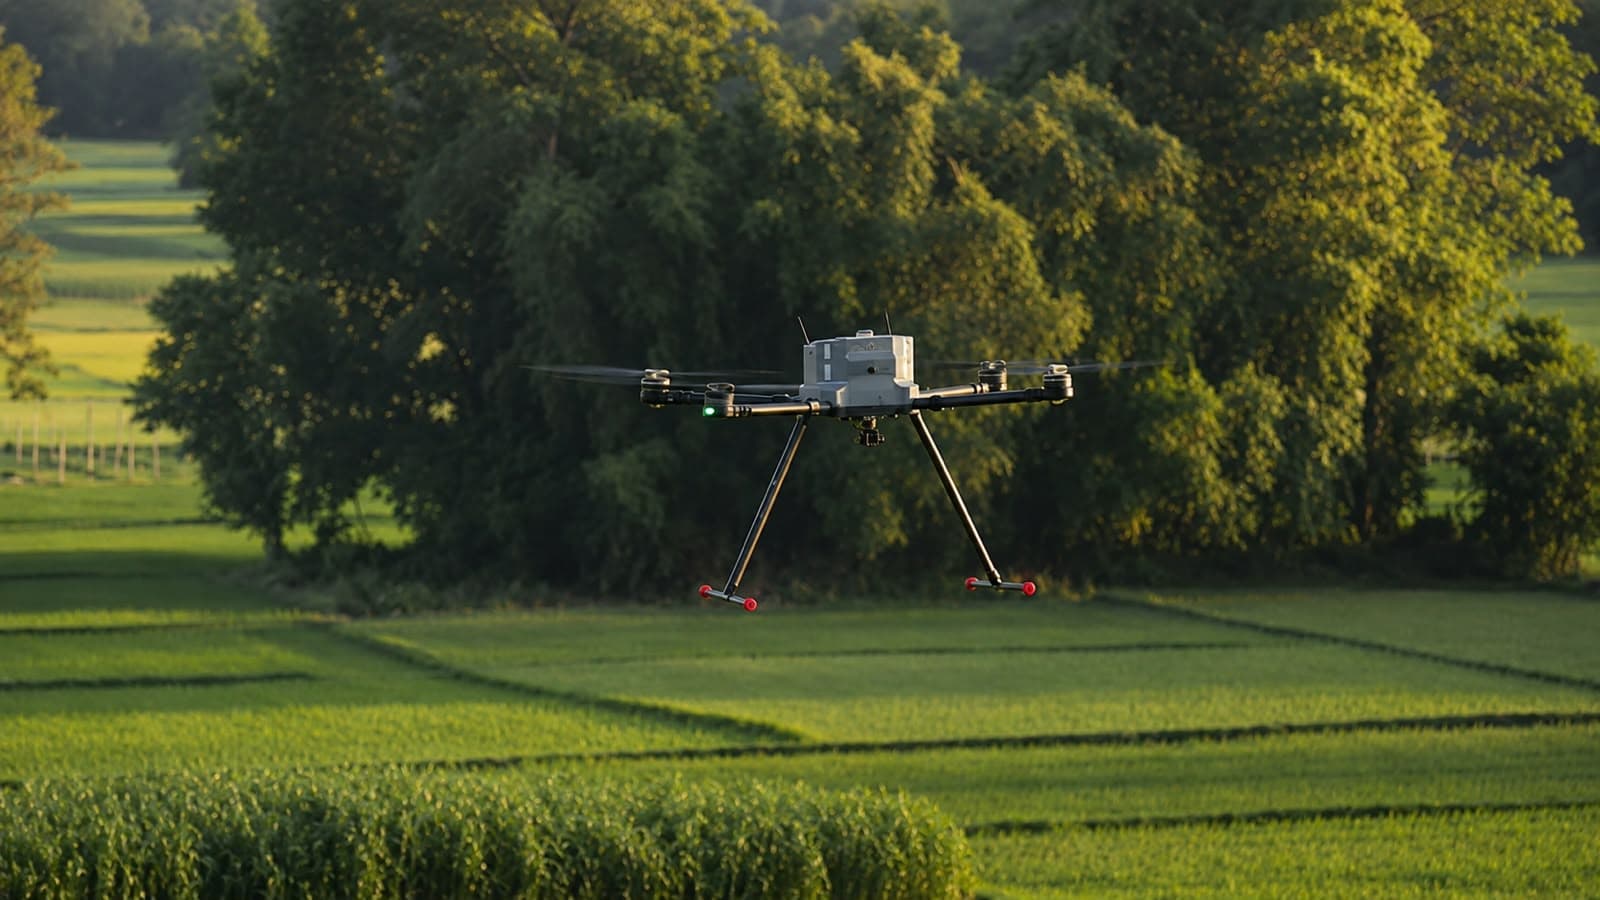
A navigation and telemetry environment for testing localization, autonomous motion, and robot behavior before hardware deployment.
A compact mobile robotics platform for experimenting with closed-loop motion control and embedded-to-robot middleware communication.
A collaborative hackathon project using AI to create a more engaging way to experience Janakpur culture and the Maithili language.
About
I'have completed my bachelor's degree at Tribhuvan University, IOE Purwanchal Campus, while gaining hands-on industry experience at GarudX Multipurpose.
My work sits where mechanical design, electronics, and software meet. I enjoy turning an idea into a testable system, then iterating until it behaves reliably in the real world.
How I work
Make the system tangible, then learn from it.
Simulation is useful; real-world behavior is the truth.
Good engineering should be easy for the next person to understand.